01
Define the manipulation boundary
Agree target part, reach, tools, contacts, prohibited motion and recovery criteria.
SOLUTION / AUTOMATION AND ENGINEERING TEAMS
A future robot work package needs a source-qualified model, task constraints and explicit failure handling. CV-101 provides a vocabulary for the retaining assembly, not a qualified robotic operation.
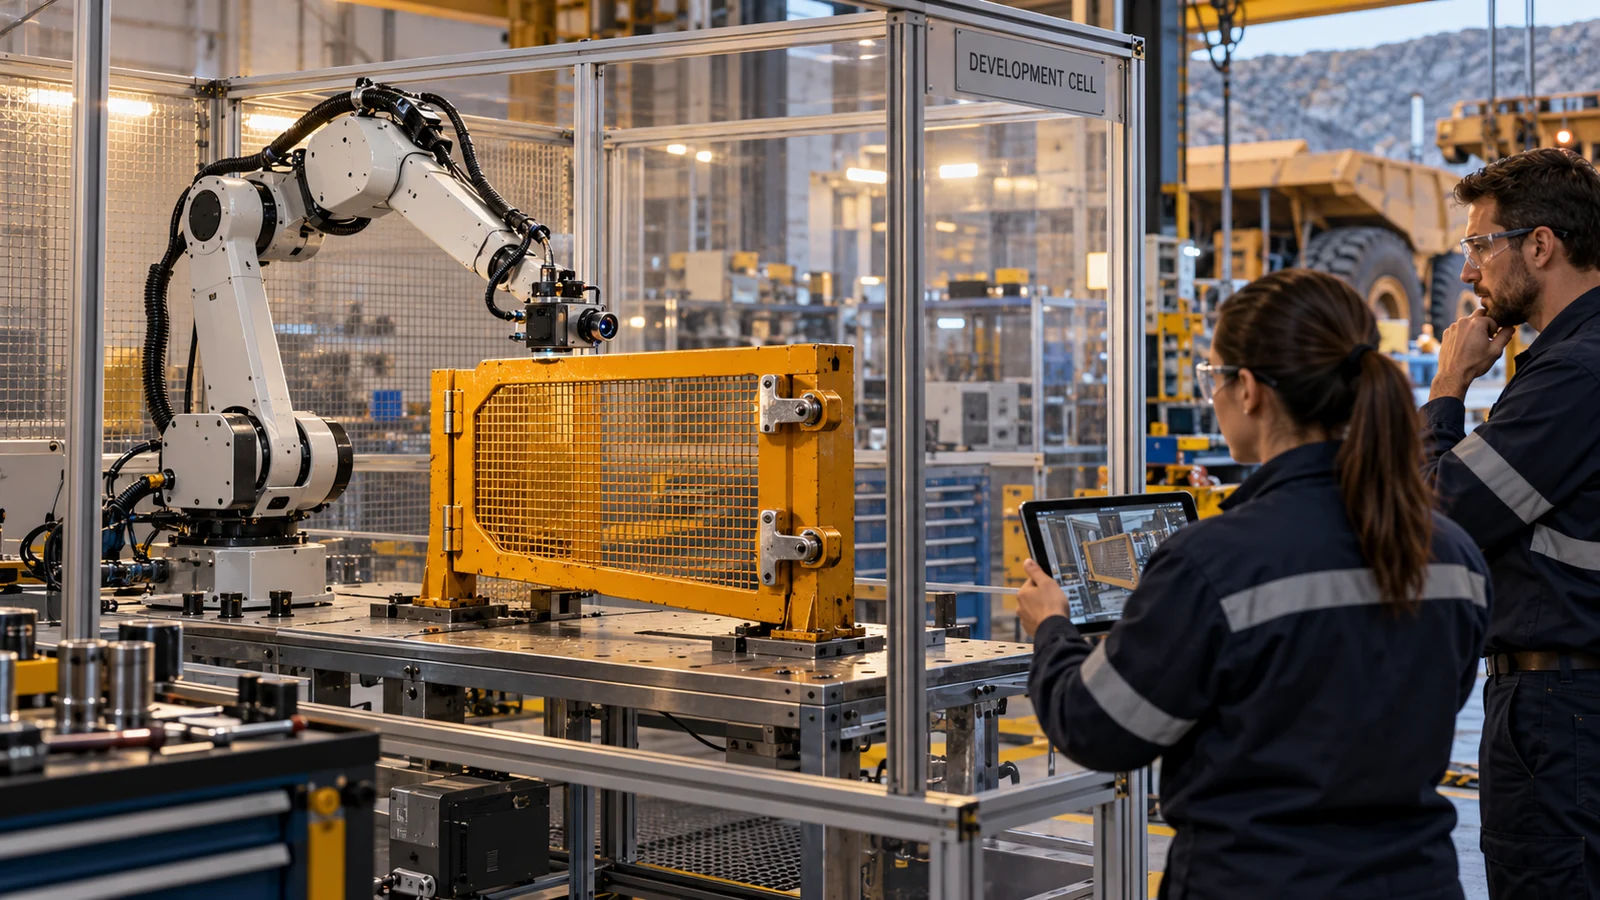
THE WORK PACKAGE
01
Agree target part, reach, tools, contacts, prohibited motion and recovery criteria.
02
Verify geometry, perception and contact assumptions with an engineering owner.
03
Move to controlled tests only after the relevant owners accept the evidence and operating constraints.
OUTPUTS TO REVIEW
ACCEPTANCE QUESTION
Development pathway only; no robot controller, digital physics or hardware qualification is implemented here.
BEGIN WITH ONE TASK
A permitted source image, a named procedure owner and one useful acceptance test make a practical starting point.